
South Korea Develops Foldable Steel Wheels for 2030 Lunar Rover Mission
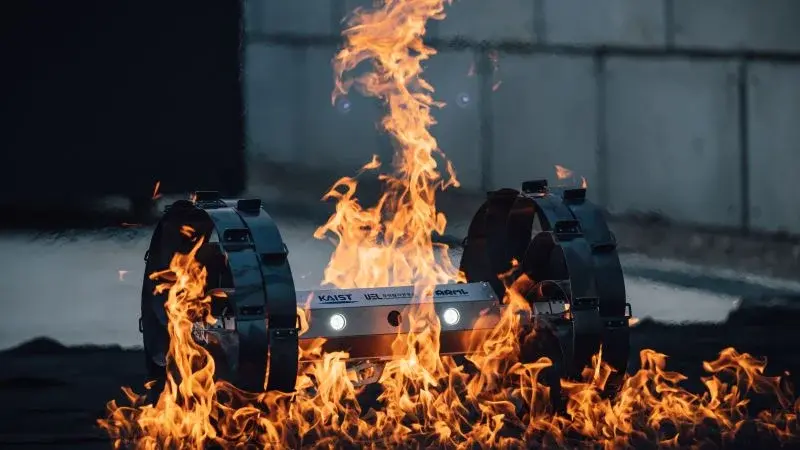
Researchers at the Korea Advanced Institute of Science & Technology (KAIST) have created a new type of airless rover wheel inspired by origami and Da Vinci bridge structures. These wheels, made from fire-resistant high-carbon steel, can shrink from 20 inches to 9 inches to fit inside a lander and expand upon landing. The technology aims to help South Korea’s planned 2030 lunar mission navigate difficult terrain, including lava tubes, while withstanding extreme temperature swings.
Key points
- KAIST researchers developed flexible, origami-inspired wheels for a lunar rover intended for a 2030 mission.
- The wheels are constructed from high-carbon steel strips arranged in a spiral to allow shape-changing without complex mechanisms.
- The design allows the wheel to compress to 9 inches for transport and expand to over 20 inches on the lunar surface.
- Testing has been conducted in caves on Jeju Island and in lab environments simulating lunar regolith and extreme temperatures.
- The project is part of South Korea’s broader space ambitions, including a 2027 budget increase of 47% for aerospace development.
Background
This development aligns with South Korea’s growing focus on space exploration, following earlier automotive and industrial innovations. While previous archive items focused on automotive design refreshes, this marks a shift toward advanced aerospace engineering. The initiative is funded by the Korea Aerospace Administration (KASA), established in 2024, which aims to make South Korea a top-five global aerospace power.
Why it matters
The success of these deployable wheels could enable exploration of lunar lava tubes, which are considered potential shelters for future human colonies due to their protection from radiation and temperature extremes. Additionally, the integration of AI for autonomous navigation suggests a move toward more independent robotic exploration, reducing reliance on Earth-based control.
What to watch
The next phase involves developing an AI-driven rover capable of autonomous navigation, led by master’s student Yiseub Yun. This system will use reinforcement learning to optimize wheel configuration and movement strategies for lunar obstacles. The ultimate goal is to deploy a rover with these wheels to the moon by 2030.
Want the full story? Read the original reporting
Read on CNN